Binary Search Trees
A binary tree is a special type of tree in which each node has at most a left successor and a right successor, or, recursively, as either empty or a root node with a left subtree and a right subtree, both of which are binary trees.
A binary tree node is typically implemented with two pointers to its successors, though it may also contains a pointer to its predecessor.
A general tree can be implemented by using an array or linked-list to point to its successors in each node, or by converting the tree into a corresponding binary tree, following the "first child : left child, next sibling : right child" mapping.
A complete binary tree can be efficiently stored in an array (as in heaps). For arbitrary binary trees, however, array storage may waste memory.
A systematic visit of the nodes of a tree is called "walk" or "traversal". For a binary tree, there are three common walk orders, all defined recursively:
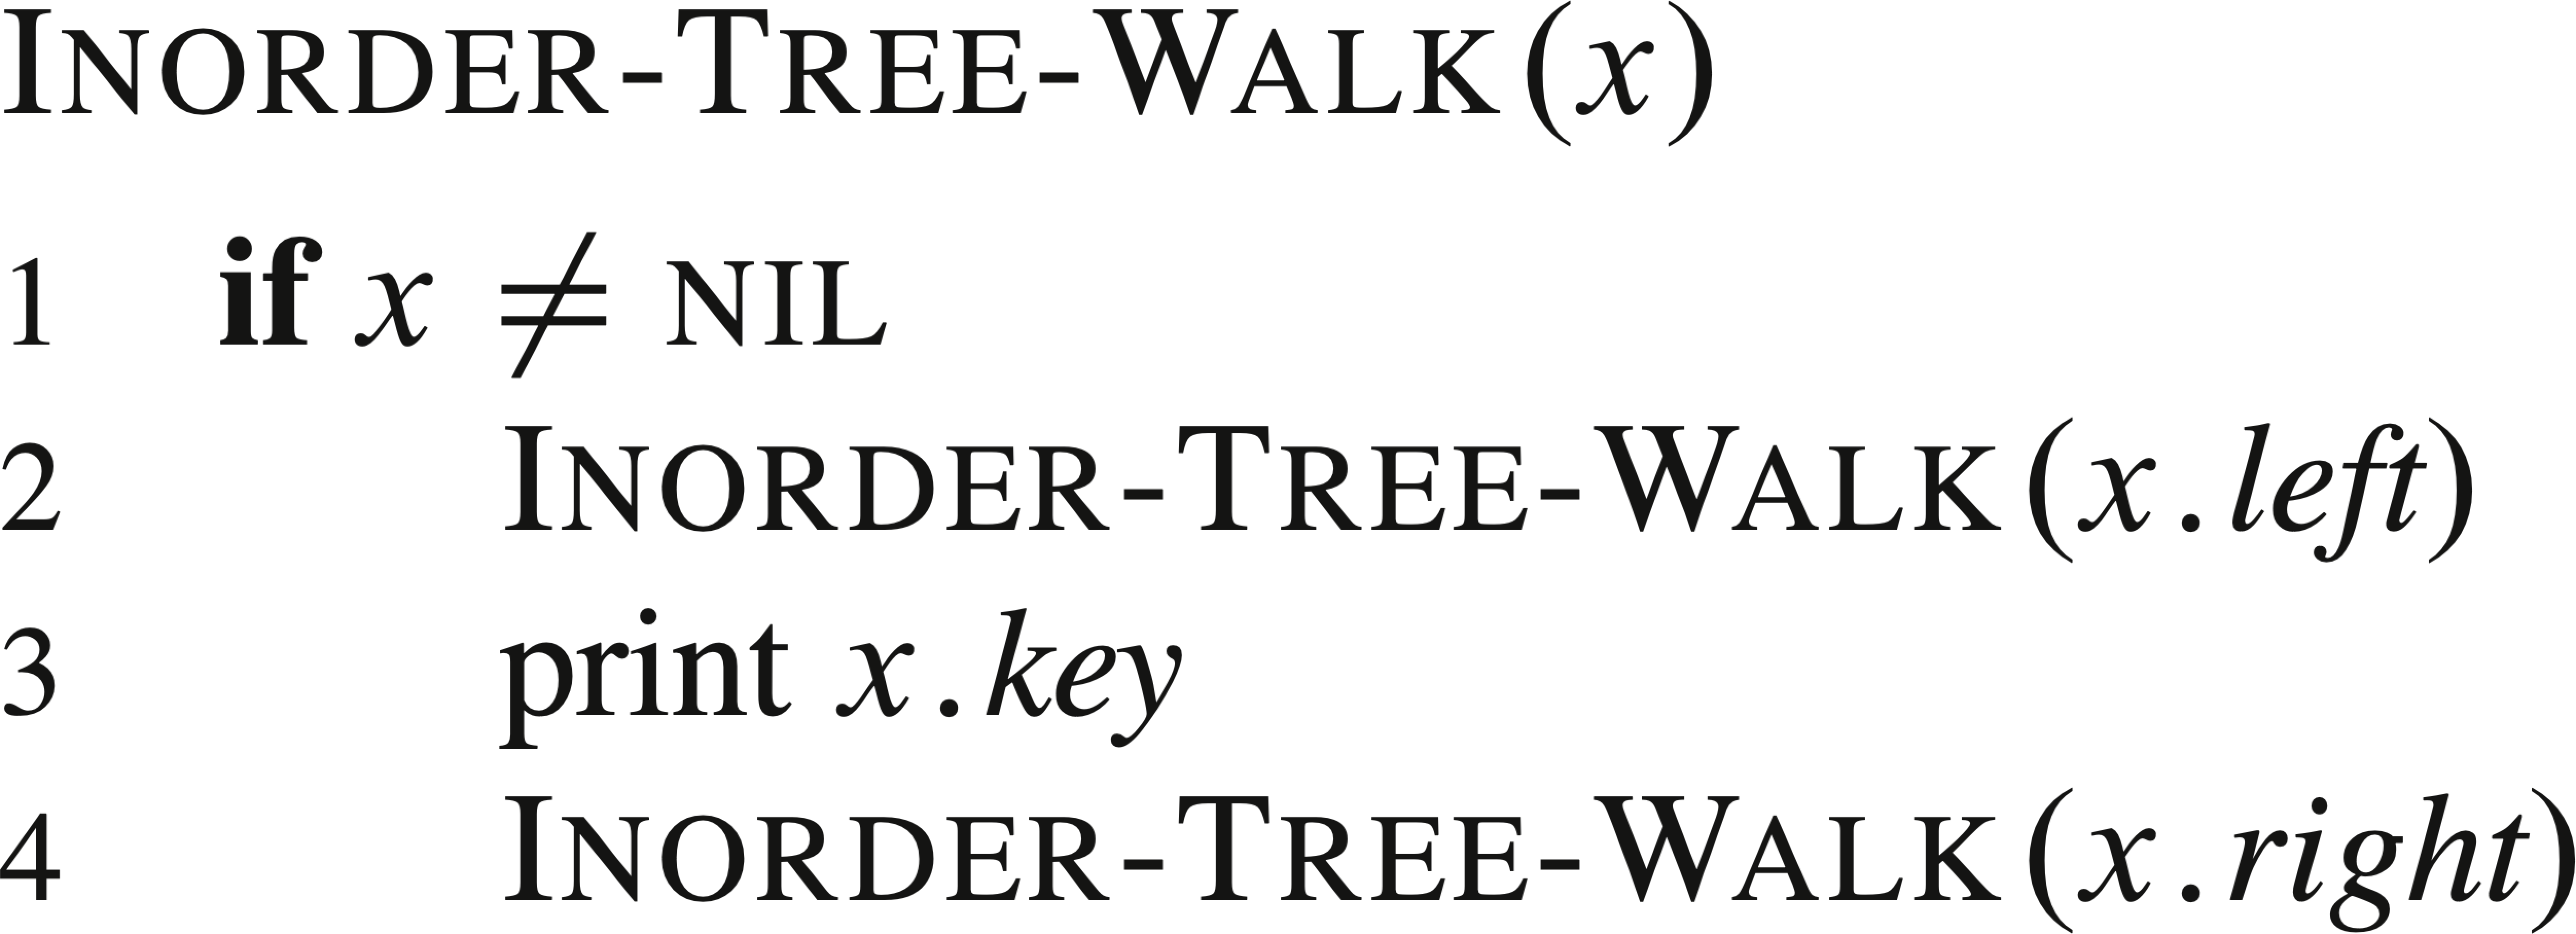
The above algorithm can be extended to visualize the structure of a binary tree by adding a parameter that indicates the recursion level and printing the appropriate indentation before each print statement.
The other two walk algorithms can be obtained from the above algorithm by changing the position of the recursive calls. These two algorithms can be extended for general trees, though "inorder" is undefined in that situation.
A useful visualization of tree walking is to trace the tree's outline counterclockwise:
Given this definition, an in order walk of a binary search tree lists all of its node in order. In this sense, BST is "horizontally sorted". By comparison, a heap is "vertically sorted", maintaining order only along parent-child paths rather than among all nodes.
Searching in a BST is analogous to binary search on a sorted array. The algorithm can be either recursive or iterative.
The path the algorithm following is from the root to a node where the key to be searched is or should be in the tree, therefore the running time is proportional to the length of the path, and the worst case running time is proportional to the height of the tree.
We can take the search for the minimum and maximum keys as special cases of the search operation. In these cases, the comparisons in the path become unnecessary, and the algorithm simply goes to the end of one direction: left for the minimum and right for the maximum.
Given a node x in a binary search tree, its (inorder) successor is the node with the smallest key greater than x.key, so in an in order tree walk this node will immediately follow x. The following algorithm requires the pointer to parent in each node. If x has a right subtree, then its successor is the minimum node in it, otherwise its successor is its closest ancestor that x is in its left subtree.
The Tree-Predecessor algorithm is symmetric to the above one.
Repeatedly calling Tree-Successor will give us a non-recursive in order tree walk algorithm.
All the search algorithms on BST run in O(h) time, where h is the height of the tree.
The following algorithm inserts node z into BST T (assume z is not already in T):
In the algorithm, x traces a path to the insertion point, and y indicates the parent of x.
The deletion algorithm is more complicated, because after a non-leaf node is deleted, the "hole" in the structure needs to be filled by another node. There are three possibilities:
This solution is realized with the help of an algorithm TRANSPLANT that replaces one subtree with root u with another subtree with root v.

In the following algorithm, z is an input argument referring to the node to be deleted from the BST T, and the local variable y refers to its successor.
Both above algorithms have run time O(h).
Since in BST all major operations have run time O(h), the height of a binary search tree determines the worst-case run time. For a binary tree with n nodes, the shortest tree (complete binary tree) has a height h = Θ(lg(n)), and the highest tree (linear list) has a height h = Θ(n). A randomly formed BST has an expected height h = Θ(lg(n)).
