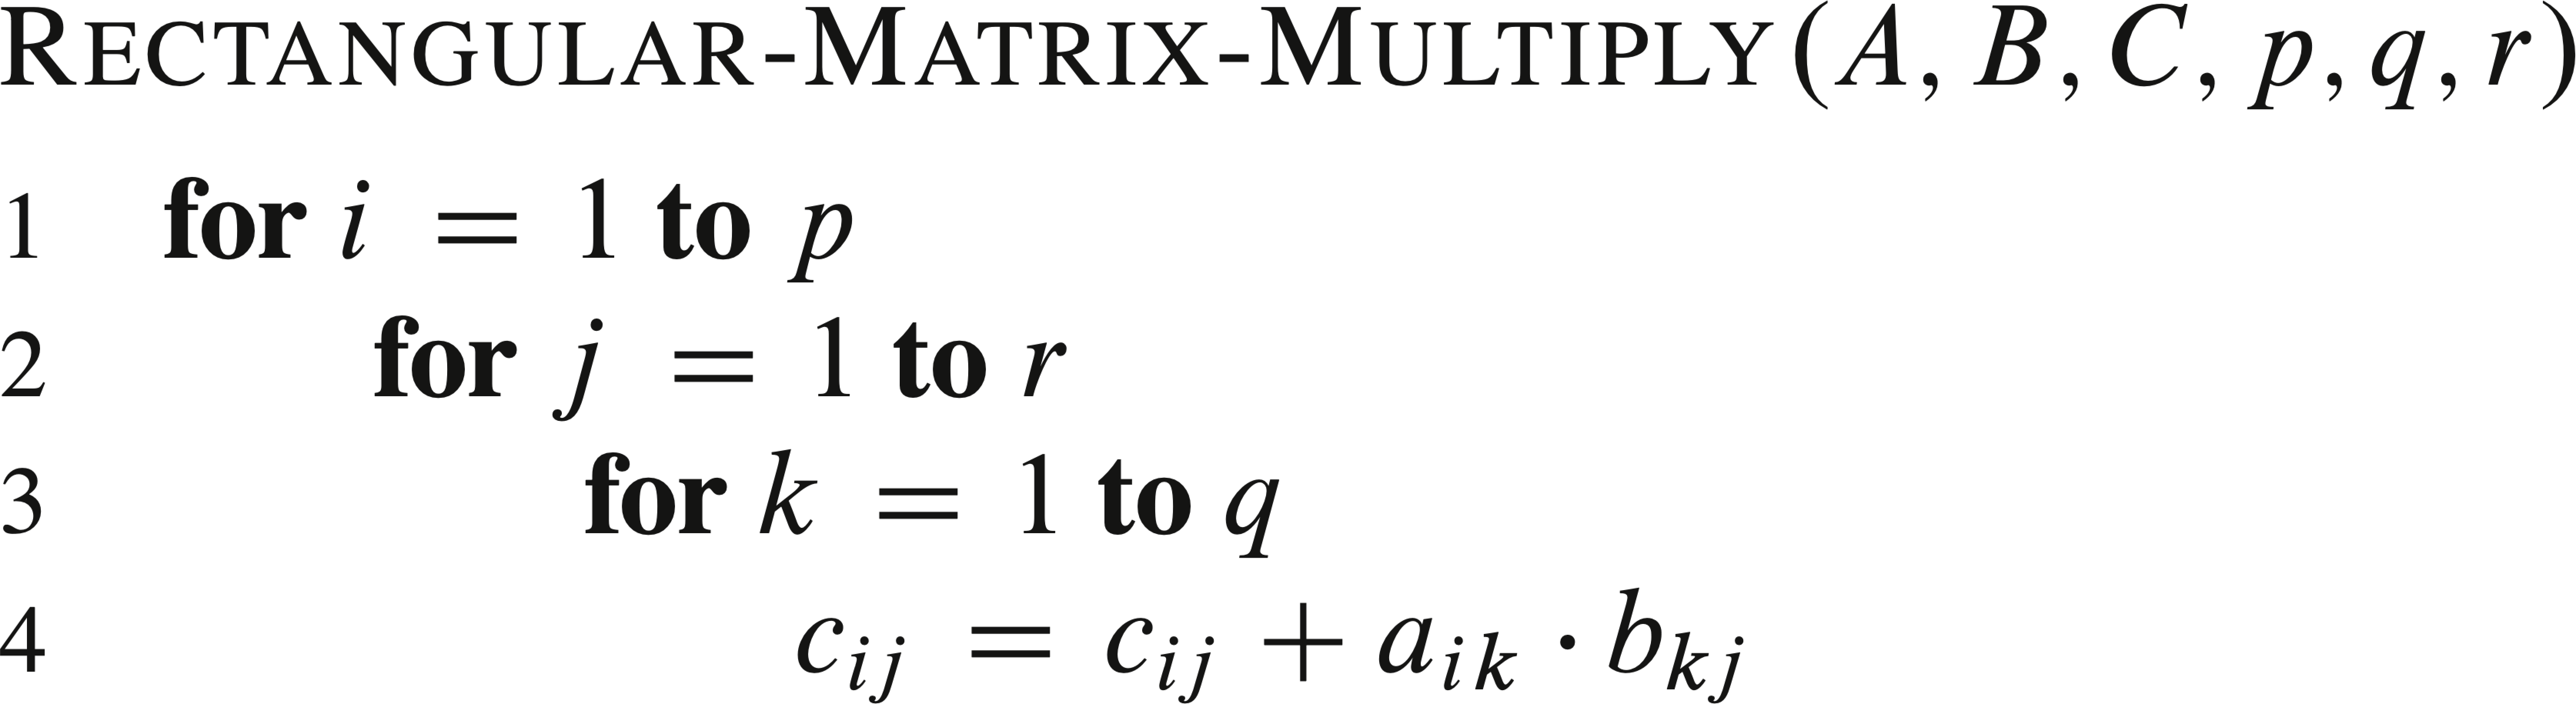
Dynamic Programming
For example, Fibonacci numbers are defined by the following recurrence:
    F(0) = 0
    F(1) = 1
    F(i) = F(i-1) + F(i-2)
A recursive algorithm derived from this definition is:
    Fibonacci-R(i)
    1  if i == 0
    2      return 0
    3  if i == 1
    4      return 1
    5  return Fibonacci-R(i-1) + Fibonacci-R(i-2)
This algorithm contains repeated calculations and is therefore inefficient. For example, to get F(4), it calculates F(3) and F(2) separately, though in calculating F(3), F(2) is already calculated. The time complexity of this algorithm is O(2i).
This algorithm can be rewritten in a "bottom-up" manner with the intermediate results saved in an array. This gives us a "dynamic programming" version of the algorithm:
Fibonacci-DP(i)
    1  A[0] = 0        // assume 0 is a valid index
    2  A[1] = 1
    3  for j = 2 to i
    4      A[j] = A[j-1] + A[j-2]
    5  return A[i]
Since each subproblem solution is computed only once, the time complexity is O(i).
This example illustrates the basic idea of dynamic programming: although the solution is defined in a top-down manner (from a problem to its subproblems), it is constructed in a bottom-up manner (from solutions of subproblems to the full solution), while intermediate results are stored to avoid repeated calculations.
Memoization is a variation of dynamic programming that keeps the efficiency, while maintaining a top-down structure.
    Fibonacci-M(i)
    1  A[0] = 0        // assume 0 is a valid index
    2  A[1] = 1
    3  for j = 2 to i
    4      A[j] = -1
    5  Fibonacci-M2(A, i)

    Fibonacci-M2(A, i)
    1  if A[i] < 0
    2      A[i] = Fibonacci-M2(A, i-1) + Fibonacci-M2(A, i-2)
    3  return A[i]
The time complexity of this algorithm is also O(i).
Dynamic programming is often used in optimization problems in which an optimal solution corresponds to a particular decomposition of the problem into subproblems. When different ways of division are compared, it is quite common that some subproblems are involved multiple times, therefore dynamic programming provides a more efficient algorithm than (direct) recursion.
The difficulty of implementing dynamic programming arises from the need to keep intermediate results and to record the structure of the optimal solution, i.e., where each partial solution comes from.
The result C contains p×r elements, each calculated from q scalar multiplications and q − 1 additions. If we count the number of scalar multiplications and use it to represent running time, then for such an operation, it is p×q×r.
To compute the product of a matrix chain A1A2...An, exactly n − 1 matrix multiplications are required. Although matrix multiplication is associative (i.e., allowing any adjacent pair to be multiplied at each step), different evaluation orders yield significantly different computational costs
Taking matrix-chain A1A2A3 as an example, if the three have sizes 10×2, 2×20, and 20×5, respectively, then the cost of (A1A2)A3 is 10×2×20 + 10×20×5 = 1400, while the cost of A1(A2A3) is 2×20×5 + 10×2×5 = 300.
In general, for matrix-chain Ai...Aj where each Ak has dimensions Pk-1×Pk, the minimum cost of the product m[i,j] can be obtained by looking for the best way to cut it into Ai...Ak and Ak+1...Aj. Therefore, we have
    m[i, j] = 0                                                if i = j
              min{ m[i,k] + m[k+1,j] + Pi-1PkPj }               if i < j
Since certain values of m[i,j] are reused many times, dynamic programming can be used to find the minimum number of operations by calculating this m value for sub-chains with increasing length, with another matrix s to keep the cutting point k for each m[i,j].
Please note that this algorithm determines the optimal order of matrix multiplications without actually performing the multiplications themselves.
Example: Given the following matrix dimensions:
A1 is 30 × 35
A2 is 35 × 15
A3 is 15 × 5
A4 is 5 × 10
A5 is 10 × 20
A6 is 20 × 25
P: [30, 35, 15, 5, 10, 20, 25]
At the end of the execution, the elements above the main diagonal in each matrix are (rotated 45 degrees counterclockwise in the figure):
This problem can be solved by either a bottom-up dynamic programming algorithm or a top-down, memoized dynamic-programming algorithm. The running time of both algorithms is Θ(n3), and the algorithm needs Θ(n2) space.
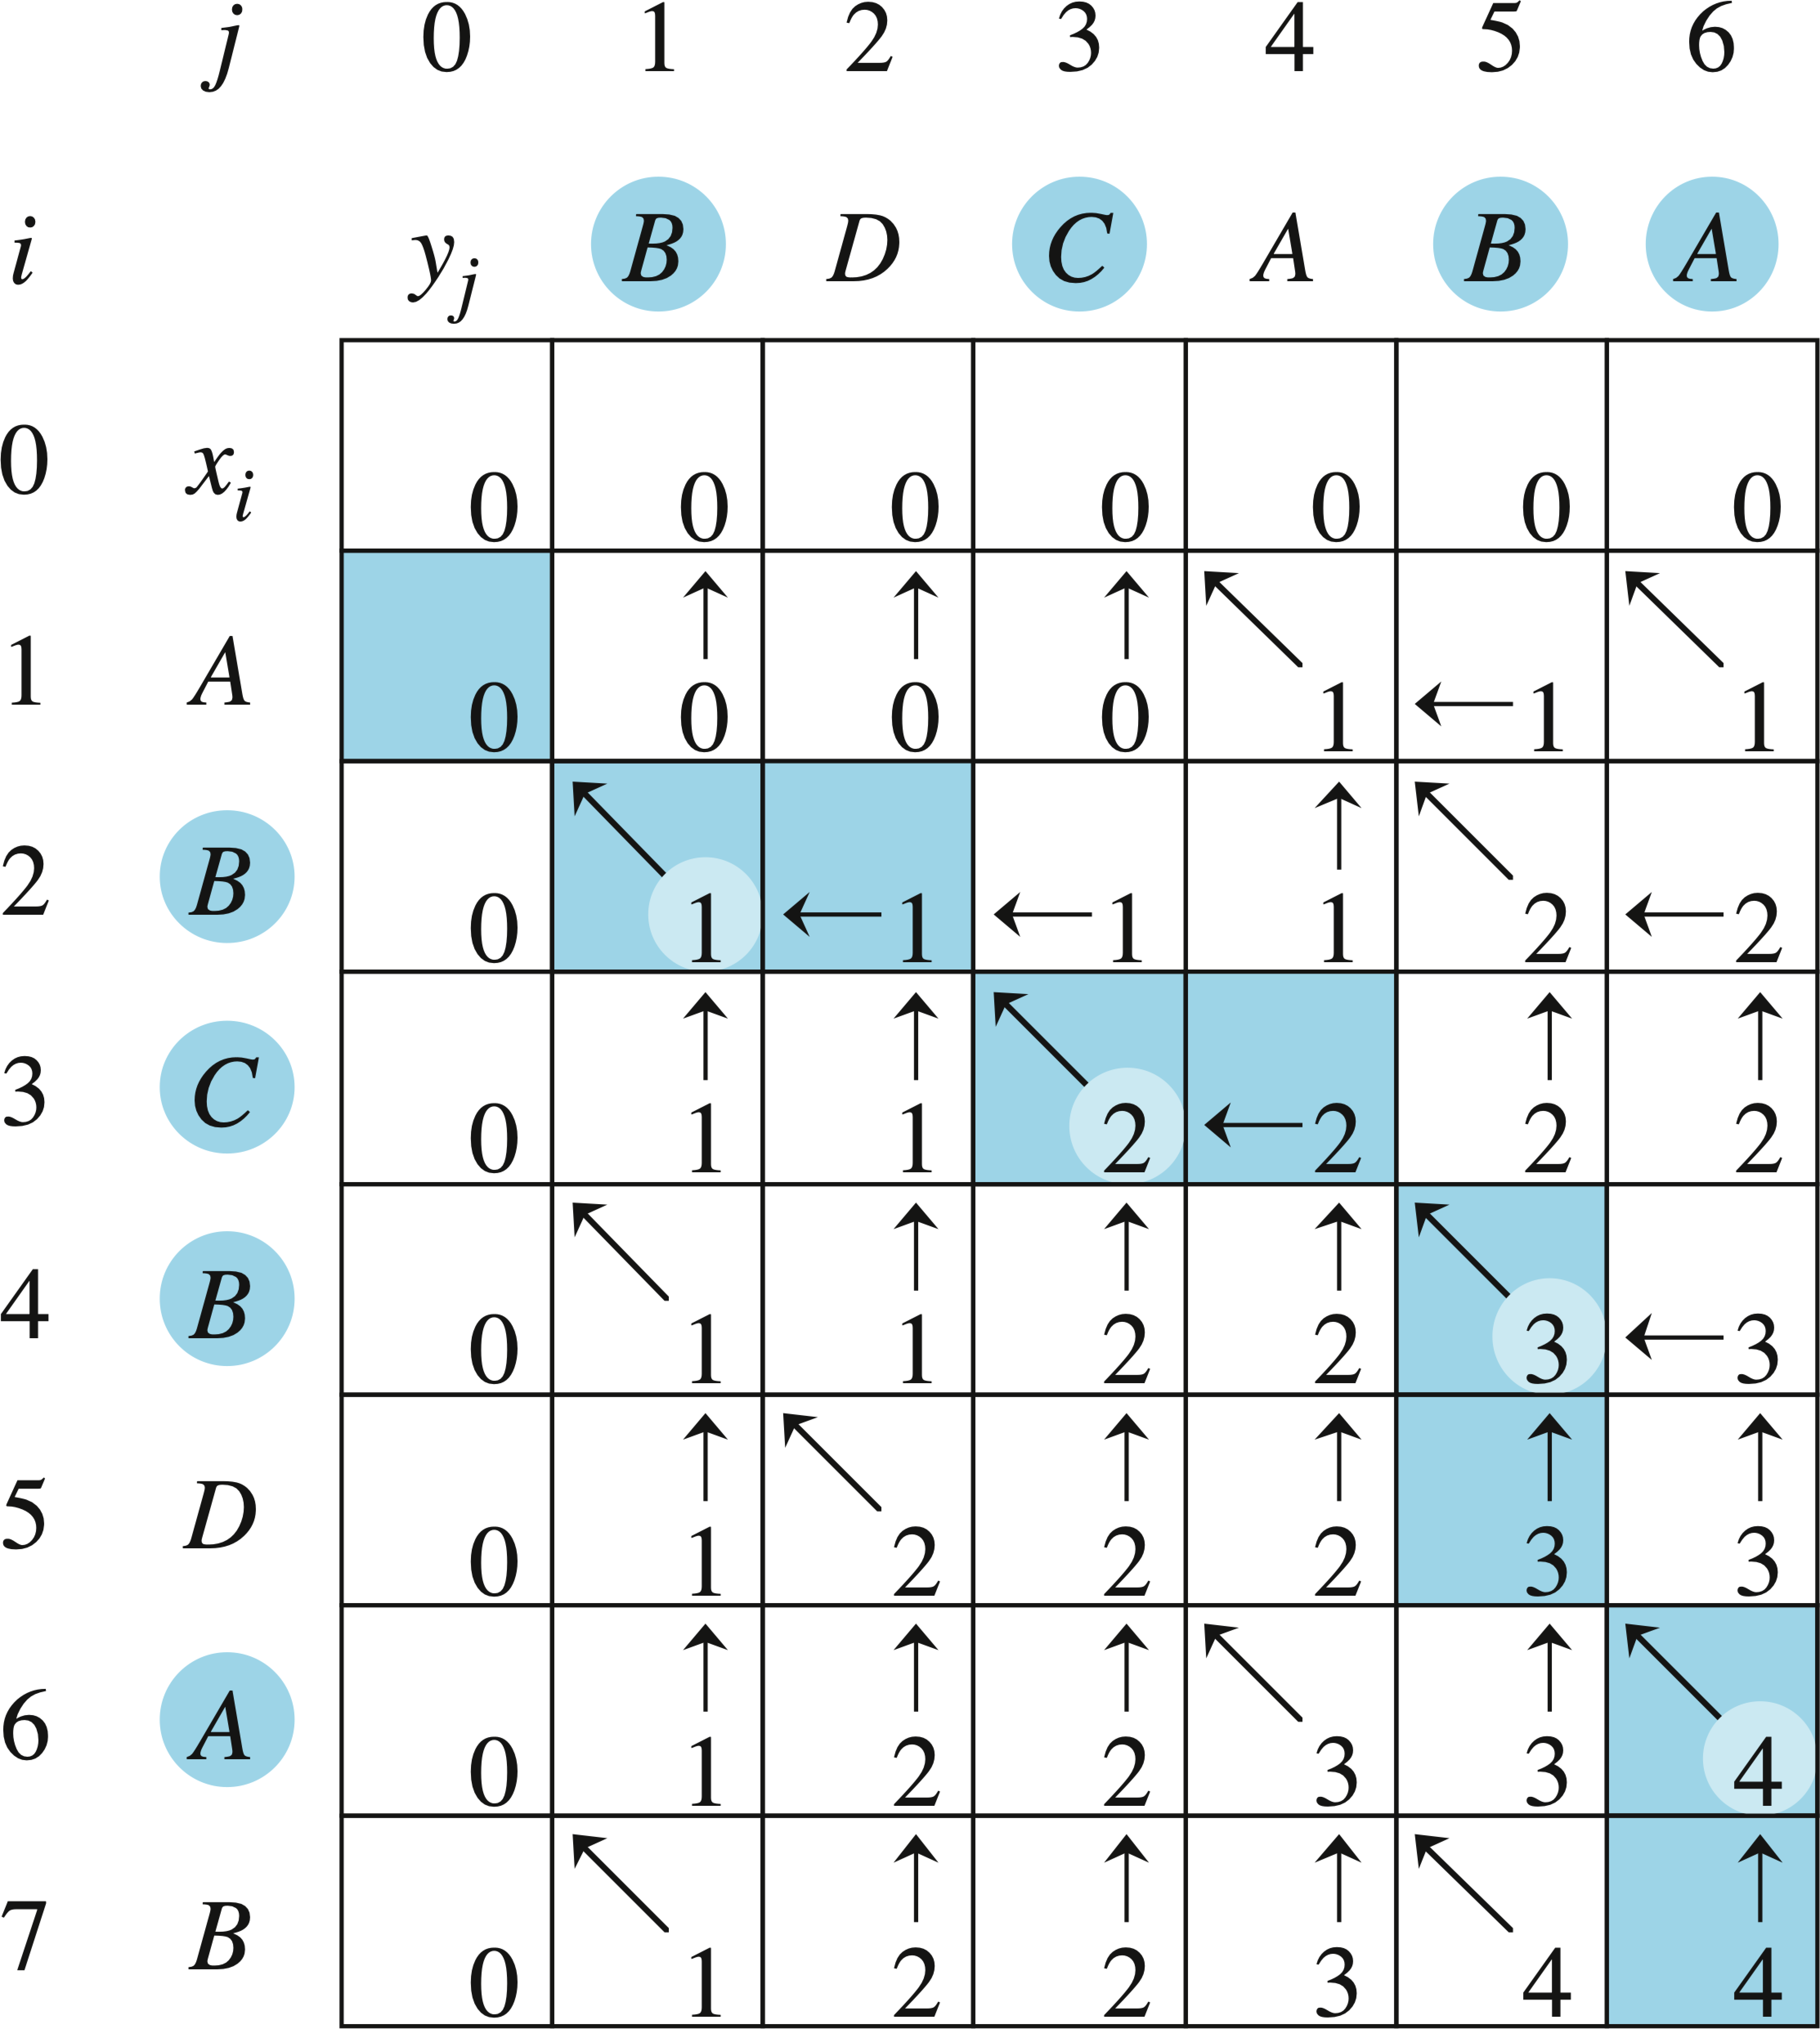
For sequences X and Y, their Longest Common Subsequence (LCS) is not necessarily contiguous in either X or Y. For example, if X is ABCBDAB and Y is BDCABA, a LCS of them is BCBA with length 4, and BCAB is another one. So the LCS is not unique, though their lengths are the same.
LCS can be recursively constructed. Let c[i, j] denote the length of a LCS of the sequences X1 ... Xi and Y1 ... Yj, then
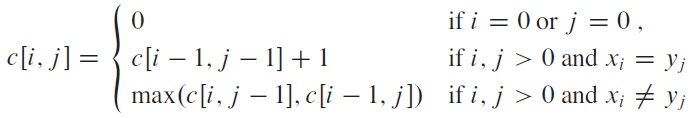
Algorithm (where the three arrowheads can be replaced by any distinct constants):
Time cost: Θ(m×n). Space cost: Θ(m×n).
Example: